NVIDIA Isaac ROS 5.0 Advances Agentic, Open Source Robotics Development
To build and deploy sophisticated robotics applications that can perceive, reason and act in dynamic environments, developers need new physical AI models and tools.
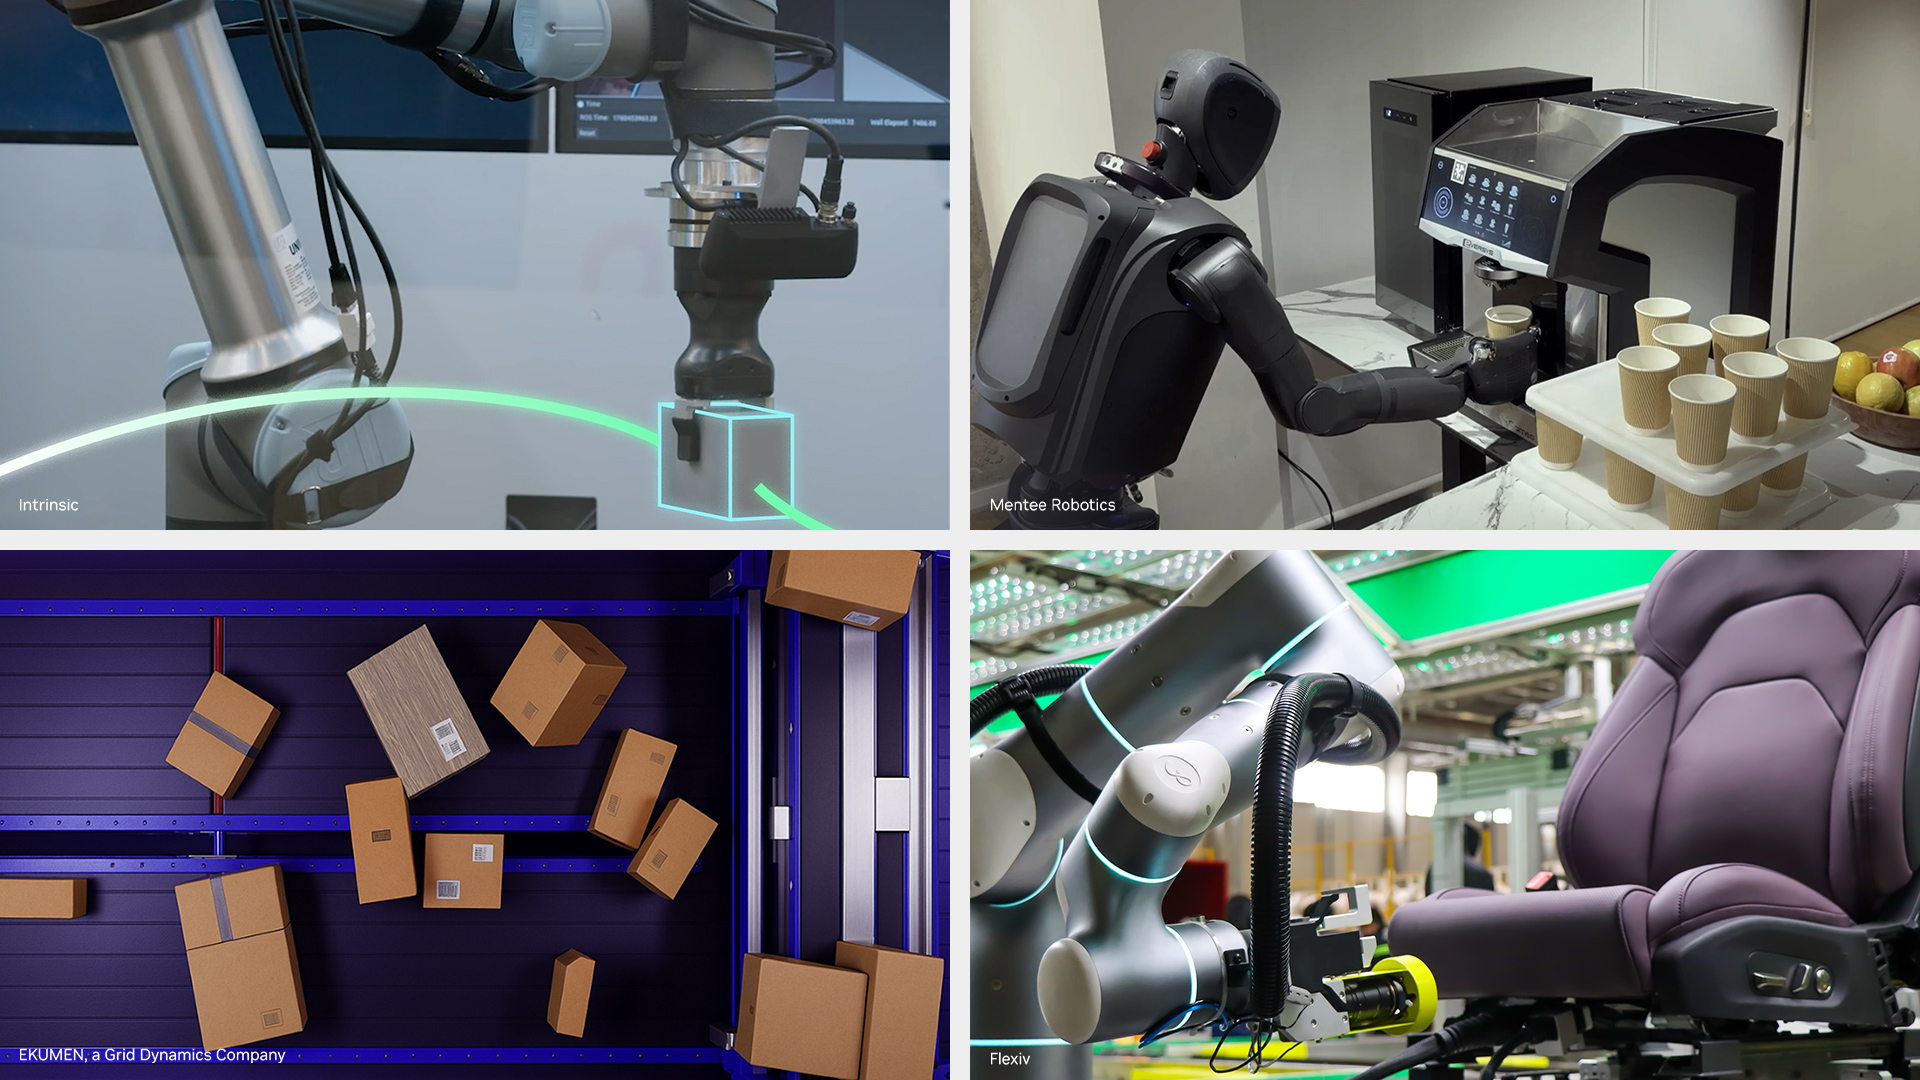
To build and deploy sophisticated robotics applications that can perceive, reason and act in dynamic environments, developers need new physical AI models and tools.
Turning a simulation idea into a working application means assembling assets, connecting physics and rendering, and checking that the scene behaves as intended. Developers are combining frontier AI models with NVIDIA Omn…
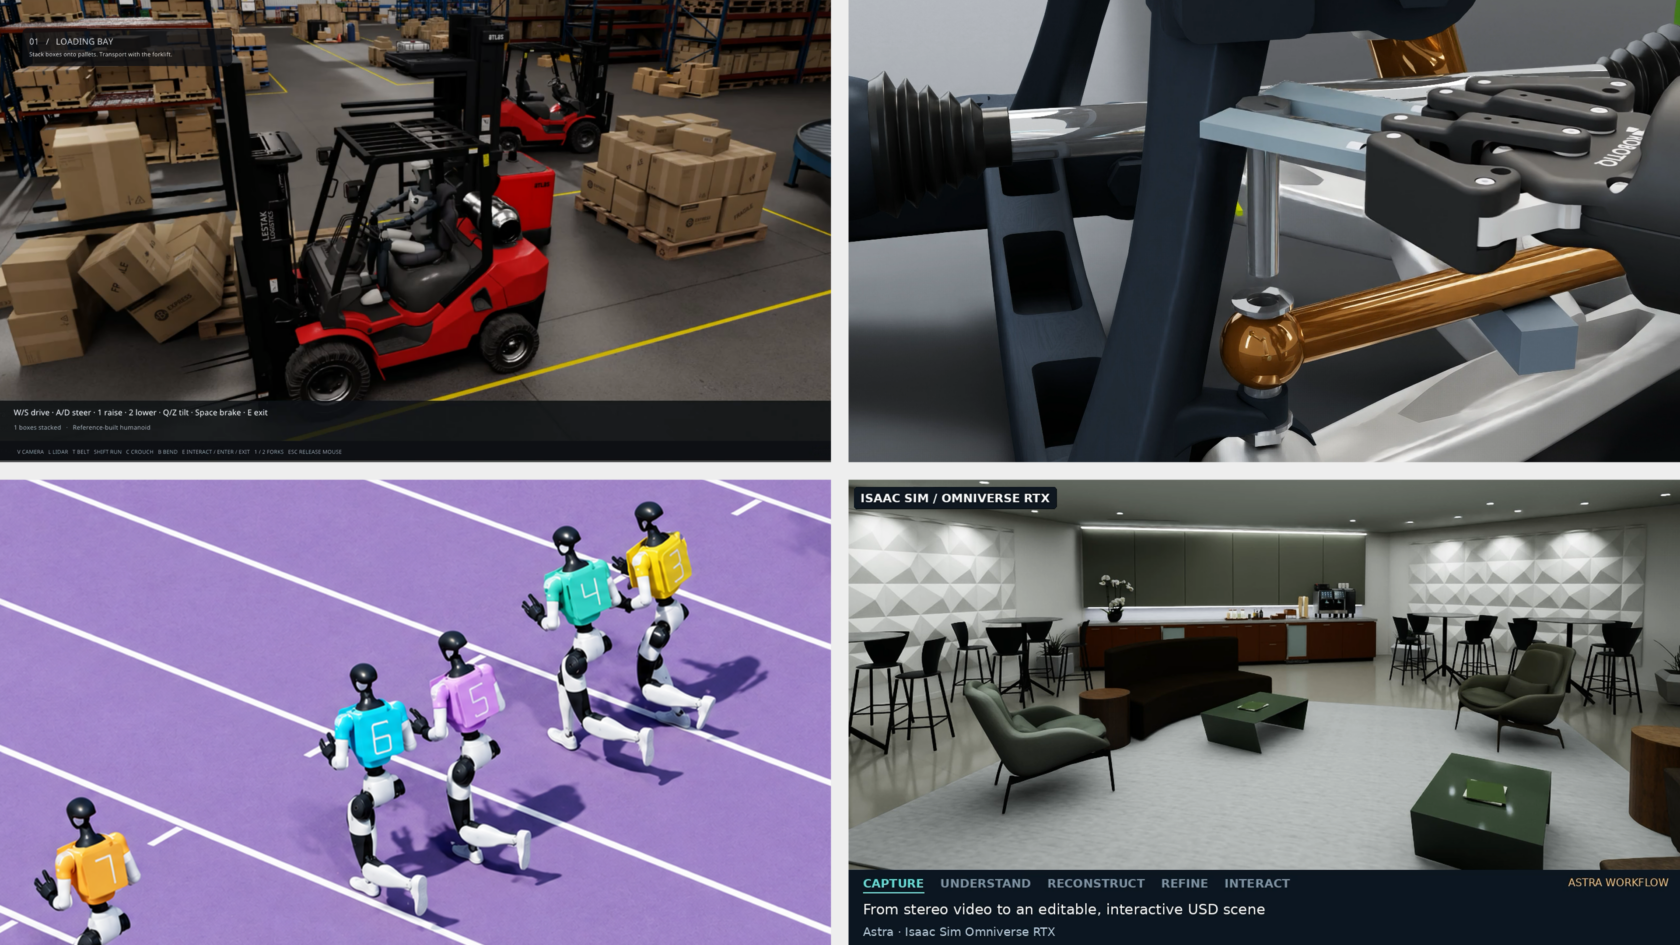
To build and deploy sophisticated robotics applications that can perceive, reason and act in dynamic environments, developers need new physical AI models and tools.
To build and deploy sophisticated robotics applications that can perceive, reason and act in dynamic environments, developers need new physical AI models and tools.
To build and deploy sophisticated robotics applications that can perceive, reason and act in dynamic environments, developers need new physical AI models and tools.
To build and deploy sophisticated robotics applications that can perceive, reason and act in dynamic environments, developers need new physical AI models and tools.
To build and deploy sophisticated robotics applications that can perceive, reason and act in dynamic environments, developers need new physical AI models and tools.
When you purchase through links on our site, we may earn an affiliate commission. Here’s how it works .
To build and deploy sophisticated robotics applications that can perceive, reason and act in dynamic environments, developers need new physical AI models and tools.
To build and deploy sophisticated robotics applications that can perceive, reason and act in dynamic environments, developers need new physical AI models and tools.