Into the Omniverse: How Developers Turn Ideas Into Simulations With Frontier AI Agents
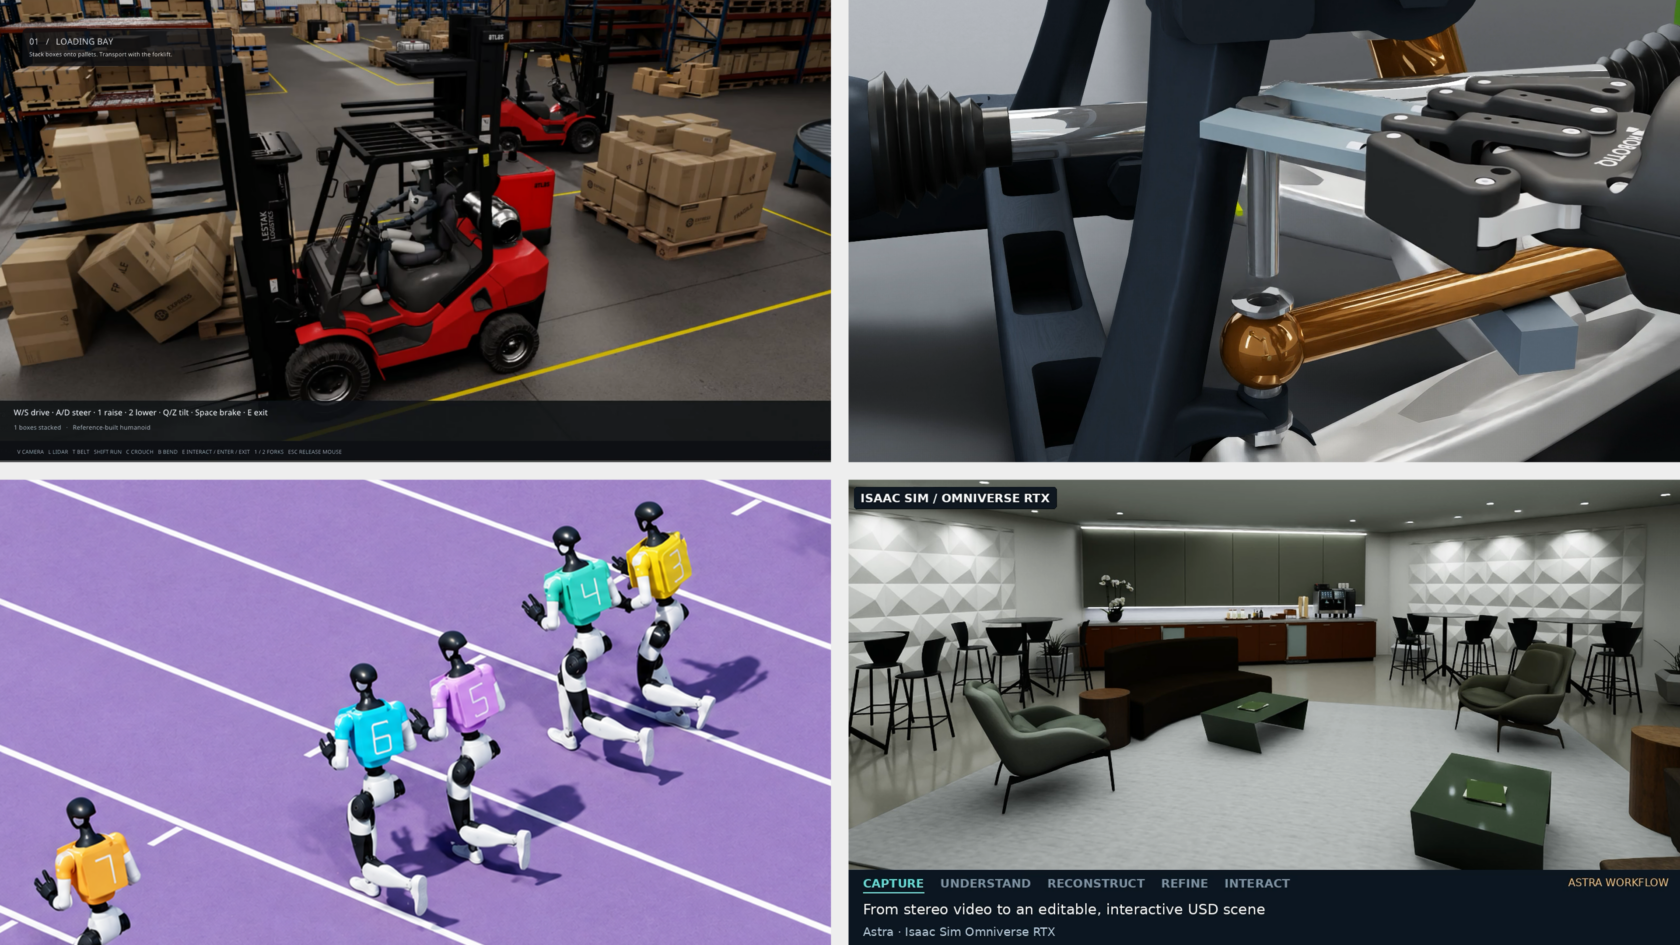
Explore a gamified, physics-based control of a humanoid robot in first- and third-person view.
Explore a gamified, physics-based control of a humanoid robot in first- and third-person view.
Explore a gamified, physics-based control of a humanoid robot in first- and third-person view.
Explore a gamified, physics-based control of a humanoid robot in first- and third-person view.
Explore a gamified, physics-based control of a humanoid robot in first- and third-person view.
Explore a gamified, physics-based control of a humanoid robot in first- and third-person view.
Explore a gamified, physics-based control of a humanoid robot in first- and third-person view.
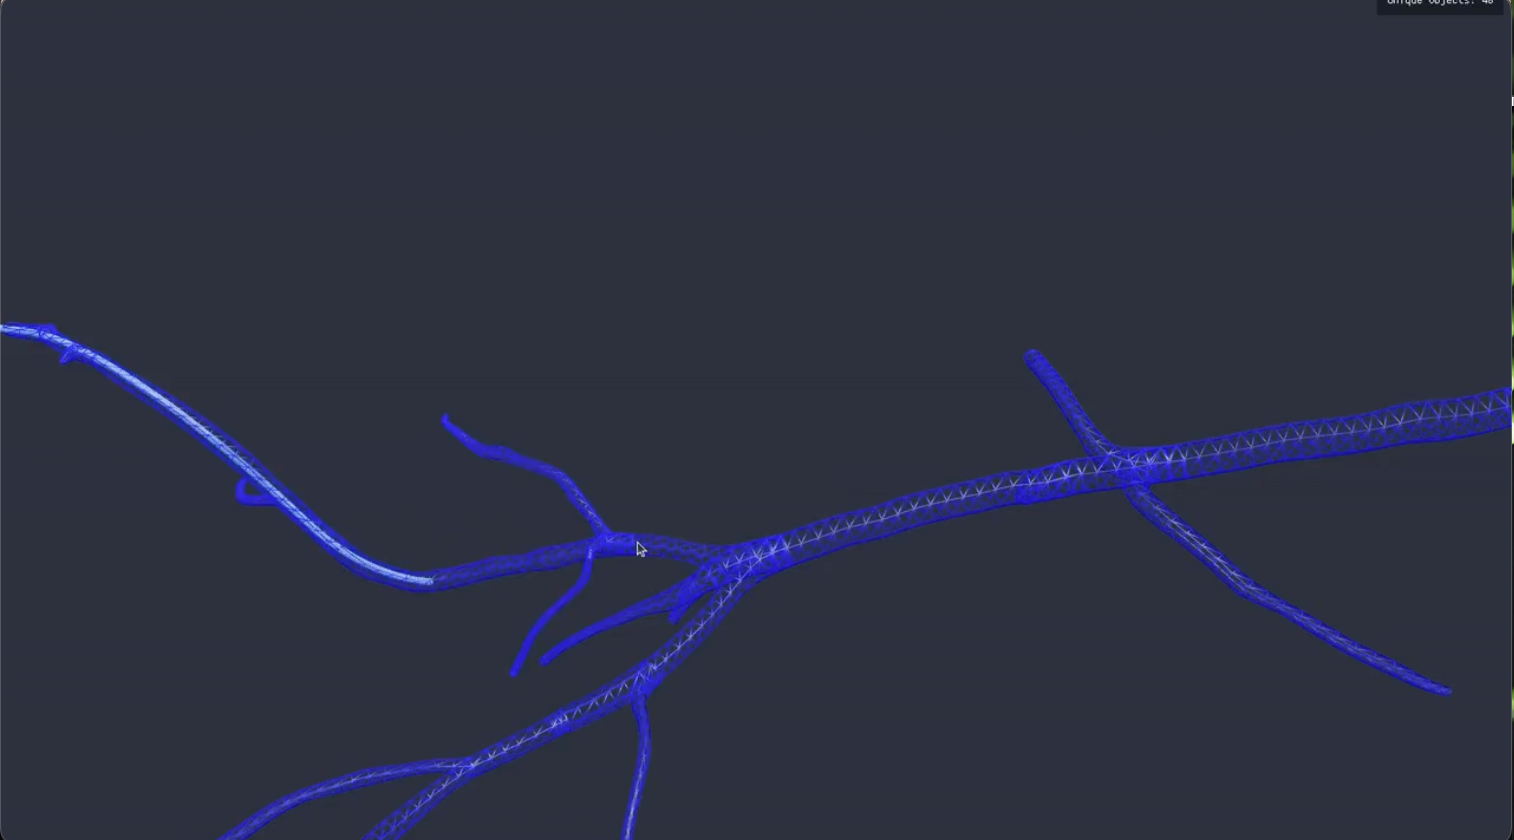
Before a healthcare robot can be useful in the real world, it has to learn how the physical world pushes back. Anatomy varies. Instruments bend, press, slip and interact with tissue. Imaging can be noisy or incomplete. A…
Before a healthcare robot can be useful in the real world, it has to learn how the physical world pushes back. Anatomy varies. Instruments bend, press, slip and interact with tissue. Imaging can be noisy or incomplete. A…
Before a healthcare robot can be useful in the real world, it has to learn how the physical world pushes back. Anatomy varies. Instruments bend, press, slip and interact with tissue. Imaging can be noisy or incomplete. A…
Before a healthcare robot can be useful in the real world, it has to learn how the physical world pushes back. Anatomy varies. Instruments bend, press, slip and interact with tissue. Imaging can be noisy or incomplete. A…